
-
Research Article
-
FOV-based Optimal Positioning and Path Planning of Quadruped Robot for Construction Site Monitoring
건설현장 모니터링을 위한 사족보행 로봇의 화각 기반 촬영 위치 및 경로 최적화 방법론
-
Hwa Sung Jang, Si On Min, Yong Chan Lee, Jae Hun Sim, Jin Gang Lee
장화성, 민시온, 이용찬, 심재훈, 이진강
- This study proposes a methodology for developing optimal positioning and path planning of a quadruped robot, addressing the operational inefficiency caused by …
본 연구는 로봇을 활용한 건설현장 모니터링 시 발생하는 무계획적 탐색과 중복 이동에 따른 운용 비효율성을 해결하기 위해, 사족보행 로봇의 촬영 위치 및 …
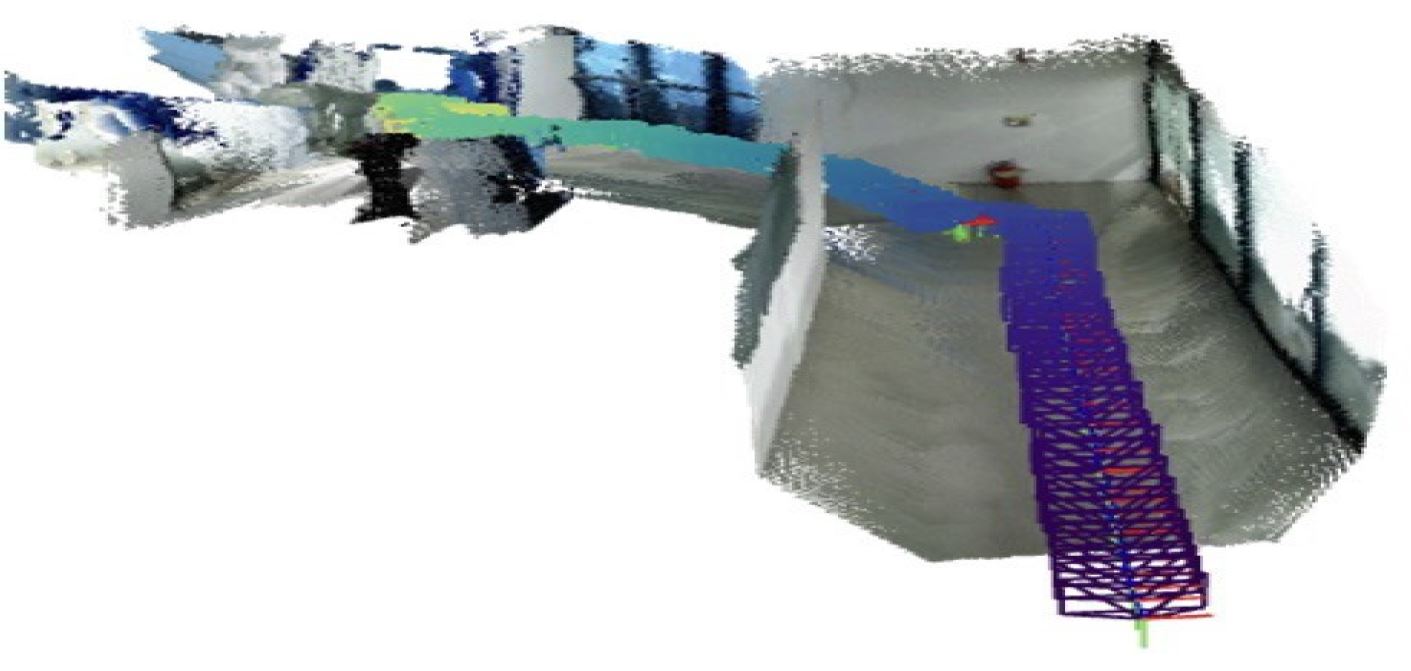
- This study proposes a methodology for developing optimal positioning and path planning of a quadruped robot, addressing the operational inefficiency caused by unplanned exploration and redundant movement during 3D spatial data acquisition at construction sites. A closed-form expression for the minimum shooting distance that guarantees full capture of a target within the camera frame was derived from the width and height of the target, the camera field of view, and the minimum safety clearance of the robot. These positions were then treated as waypoints in a multi-waypoint path optimization scheme combining the A* algorithm with the dynamic programming-based Held-Karp algorithm. The methodology was pre-validated in a BIM-based Unity simulation and demonstrated indoors at a university building using a quadruped robot (Unitree Go2). The experimental results demonstrated that, in this case study, the proposed approach achieved improvements in travel distance, travel time, and re-planning frequency compared to the built-in autonomous navigation during the 3D mapping task, and the route generated by the proposed algorithm matched the most efficient path among candidate visiting orders in the multi-waypoint shooting task.
- COLLAPSE
본 연구는 로봇을 활용한 건설현장 모니터링 시 발생하는 무계획적 탐색과 중복 이동에 따른 운용 비효율성을 해결하기 위해, 사족보행 로봇의 촬영 위치 및 경로 최적화 방법론을 제안한다. 이는 촬영 대상의 폭·높이, 카메라 화각, 로봇의 최소 안전거리로부터 대상을 화면에 온전히 포착하는 최소 촬영거리를 산정하고, 이를 경유지로 삼아 A* 알고리즘과 Held-Karp 알고리즘을 통해 최적 경로를 도출한다. 제안한 방법론의 효과를 검증하기 위해, BIM기반 시뮬레이션을 수행하고, 대학 건물 실내에서 사족보행 로봇(Unitree Go2)을 이용해 실증하였다. 제안한 방법론으로 도출한 경로로 이동했을 때, 사족보행 로봇을 활용한 3D 공간지도 데이터를 수집하는 데 필요한 이동거리·주행시간·경로 재탐색 횟수 측면에서 기본 자율주행 방식 대비 개선 효과를 나타내었다. 또한, 복수 경유지 촬영 작업에서도 제안 알고리즘이 산출한 경로가 후보 동선 중 가장 효율적인 경로와 일치하는 결과를 확인하였다.
-
FOV-based Optimal Positioning and Path Planning of Quadruped Robot for Construction Site Monitoring
-
Research Article
-
Temporal Consistency-Based Data Selection for Active Learning in Construction Site Object Detection
건설현장 객체 탐지를 위한 시간적 일관성 기반 능동학습 데이터 선정
-
Si Heon Lee, Jung Won Lee, Ji Won Jeong, Seung Jun Ahn
이시흔, 이중원, 정지원, 안승준
- Continuous construction-site video monitoring requires object detectors that adapt to changing site conditions under limited annotation budgets. This study proposes an Interpolation …
건설현장의 지속적인 영상 모니터링을 위해서는 제한된 라벨링 예산 내에서 변화하는 현장 조건에 대응하기 위한 객체 탐지 모델이 필요하다. 본 연구는 전후 프레임의 …
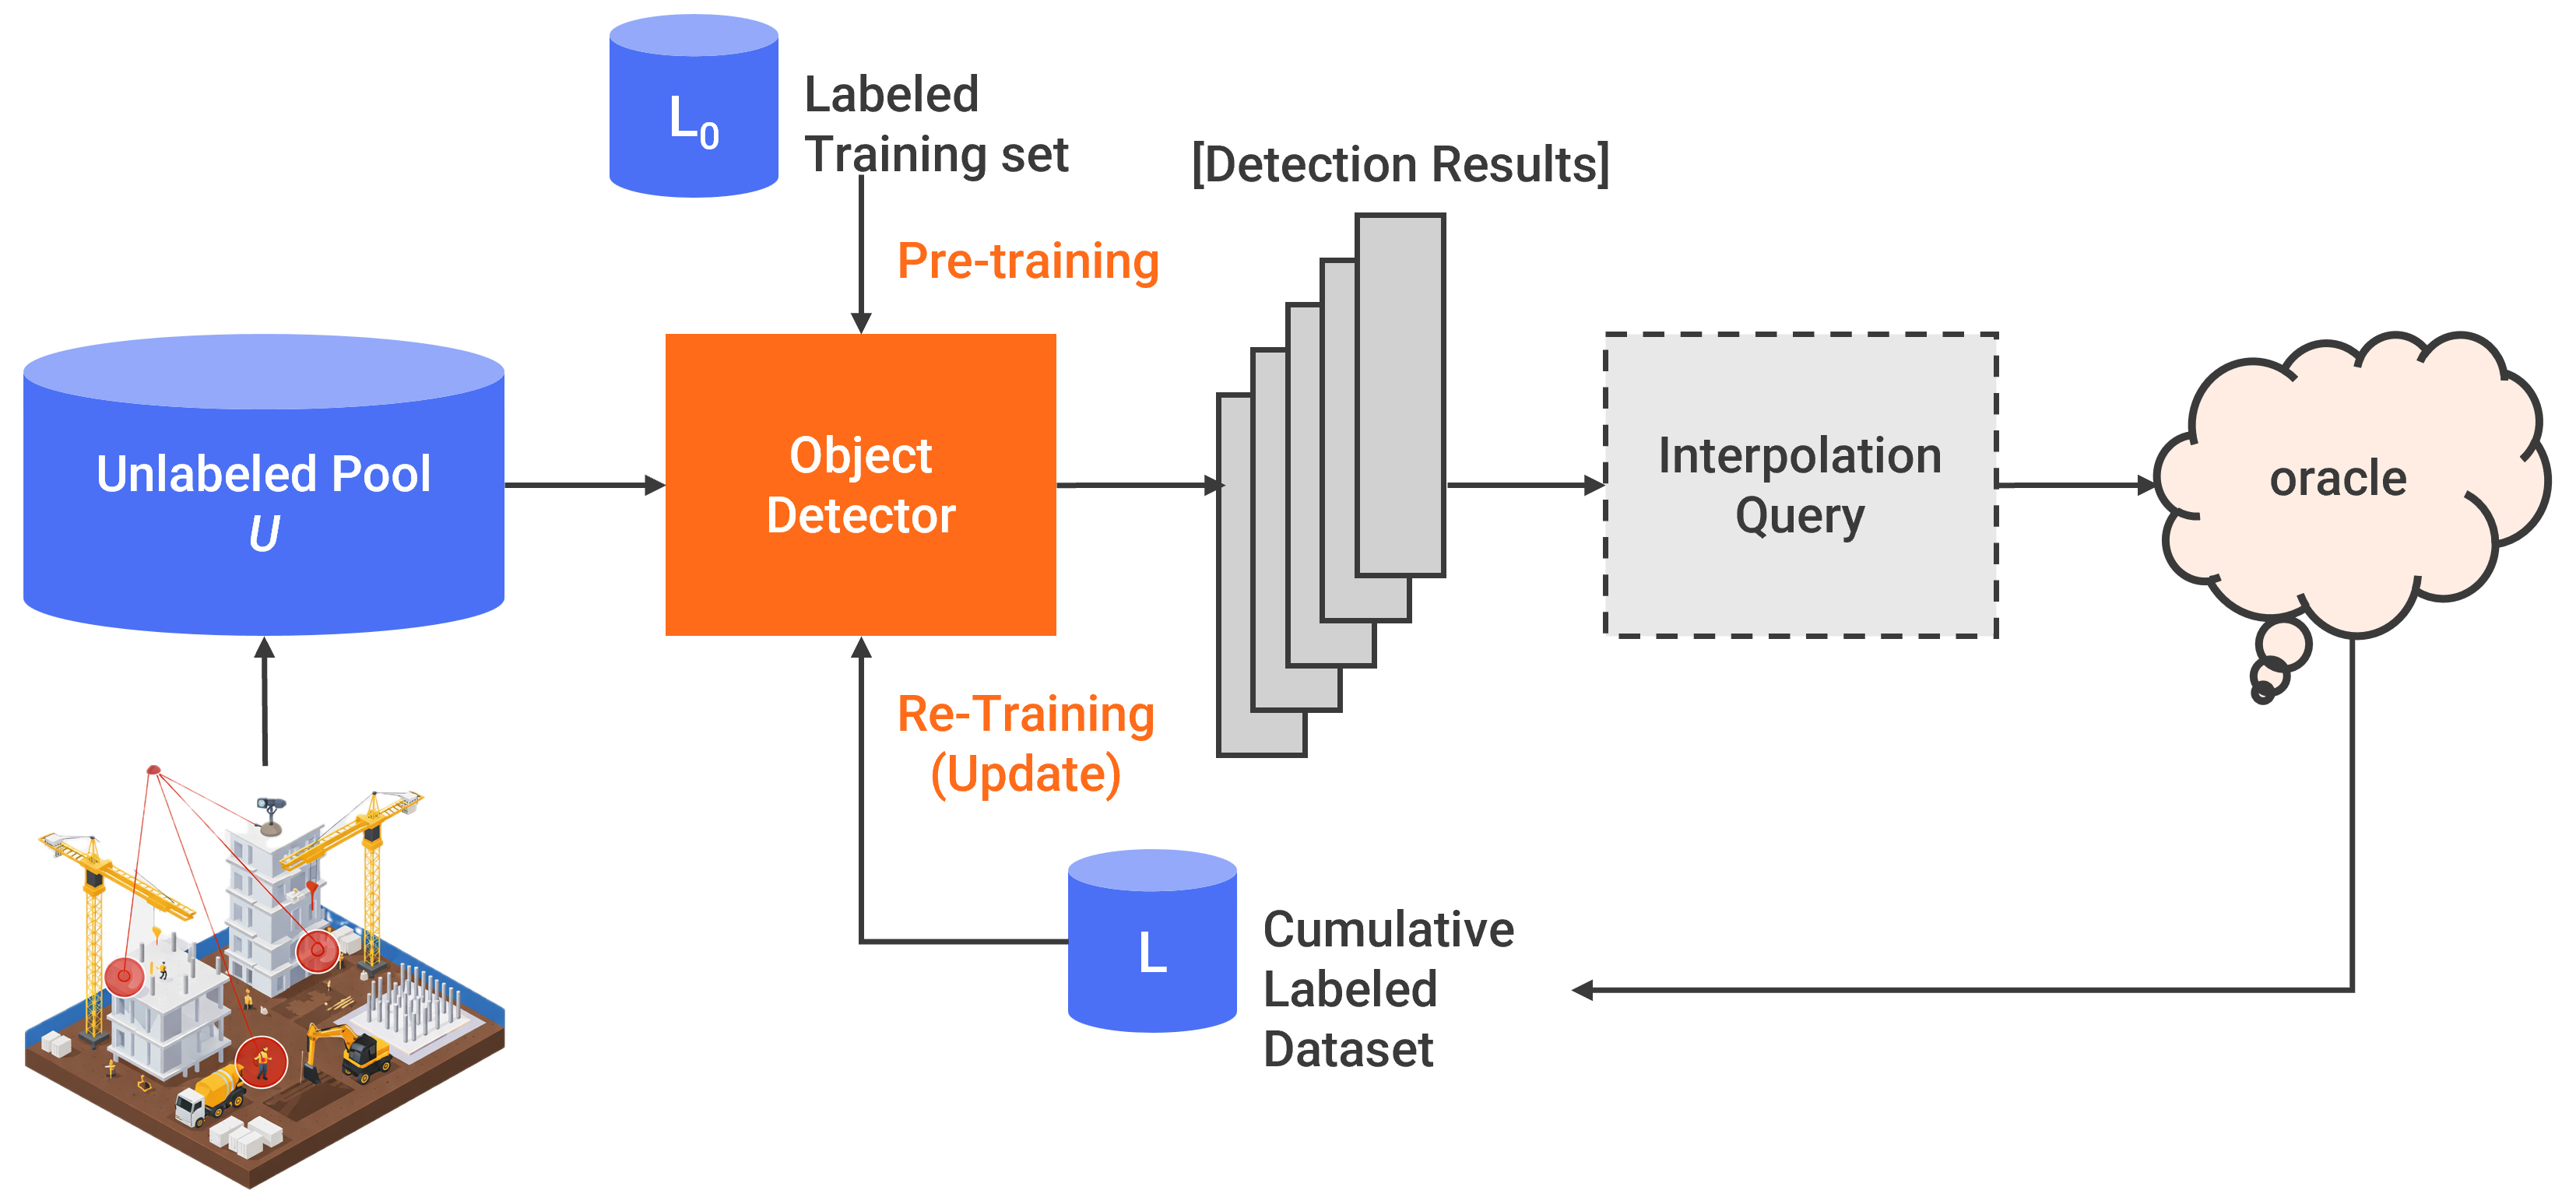
- Continuous construction-site video monitoring requires object detectors that adapt to changing site conditions under limited annotation budgets. This study proposes an Interpolation query that selects frames containing potential missed detections by matching and interpolating bounding boxes from surrounding frames. The query was incorporated into active learning and compared with random sampling using ten days of video from a single construction site under equal daily frame budgets. Frame hit rates were approximately 63.0–99.0%, and proposal box precision was approximately 50–88%. Although its advantage over random sampling was not sustained on the cumulative evaluation dataset, the method achieved higher next-day mAP50 in seven of ten transitions, with a maximum gain of 7.5 percentage points. These findings suggest that temporal consistency-based sampling of potential missed detections may improve next-day generalization under limited annotation budgets.
- COLLAPSE
건설현장의 지속적인 영상 모니터링을 위해서는 제한된 라벨링 예산 내에서 변화하는 현장 조건에 대응하기 위한 객체 탐지 모델이 필요하다. 본 연구는 전후 프레임의 바운딩 박스를 매칭·보간하여 미탐 후보를 선별하는 Interpolation 쿼리를 제안한다. 이를 능동학습 프레임워크에 적용하고 단일 건설현장에서 수집한 10일간의 영상을 이용하여 동일한 일별 프레임 예산 내에서 무작위 선별과 비교하였다. 프레임 적중률은 약 63.0–99.0%, 제안 박스 정밀도는 약 50.0–88.0%로 나타났다. 누적 평가 데이터셋에서는 무작위 선별 대비 우위가 유지되지 않았으나, 다음날 평가에서는 10개 전이 구간 중 6개에서 더 높은 mAP50을 기록하였으며 최대 차이는 8.9%p였다. 이러한 결과는 시간적 일관성 기반 미탐 선별이 제한된 라벨링 예산 내에서 다음날 일반화 성능의 개선에 기여할 가능성을 보여준다.
-
Temporal Consistency-Based Data Selection for Active Learning in Construction Site Object Detection

Journal Informaiton
 Journal of Construction Automation and Robotics
 Korean Society of Automation and Robotics in Construction
(사)한국건설자동화·로보틱스학회
510, Jae Sung Civil Engineering Building, 222, Wangsimni-ro, Seongdong-gu, Seoul, Republic of Korea
Tel: 02-2220-4497 / E-mail: ksarc2021@ksarc.or.kr Copyright© Korean Society of Automation and Robotics in Construction. Powered by APUB
Tel: 02-2220-4497 / E-mail: ksarc2021@ksarc.or.kr Copyright© Korean Society of Automation and Robotics in Construction. Powered by APUB